Leibniz-Handschriften zur Mechanik: Dynamika LH 37, 5, fol. 114r
Machine transcription. Not an edition. Errors are expected: about 8% character error rate on Latin and French lines, higher on German. Mean line confidence on this page: 0.78.
Original at the GWLB · Page image · Annotations (IIIF) · Download text
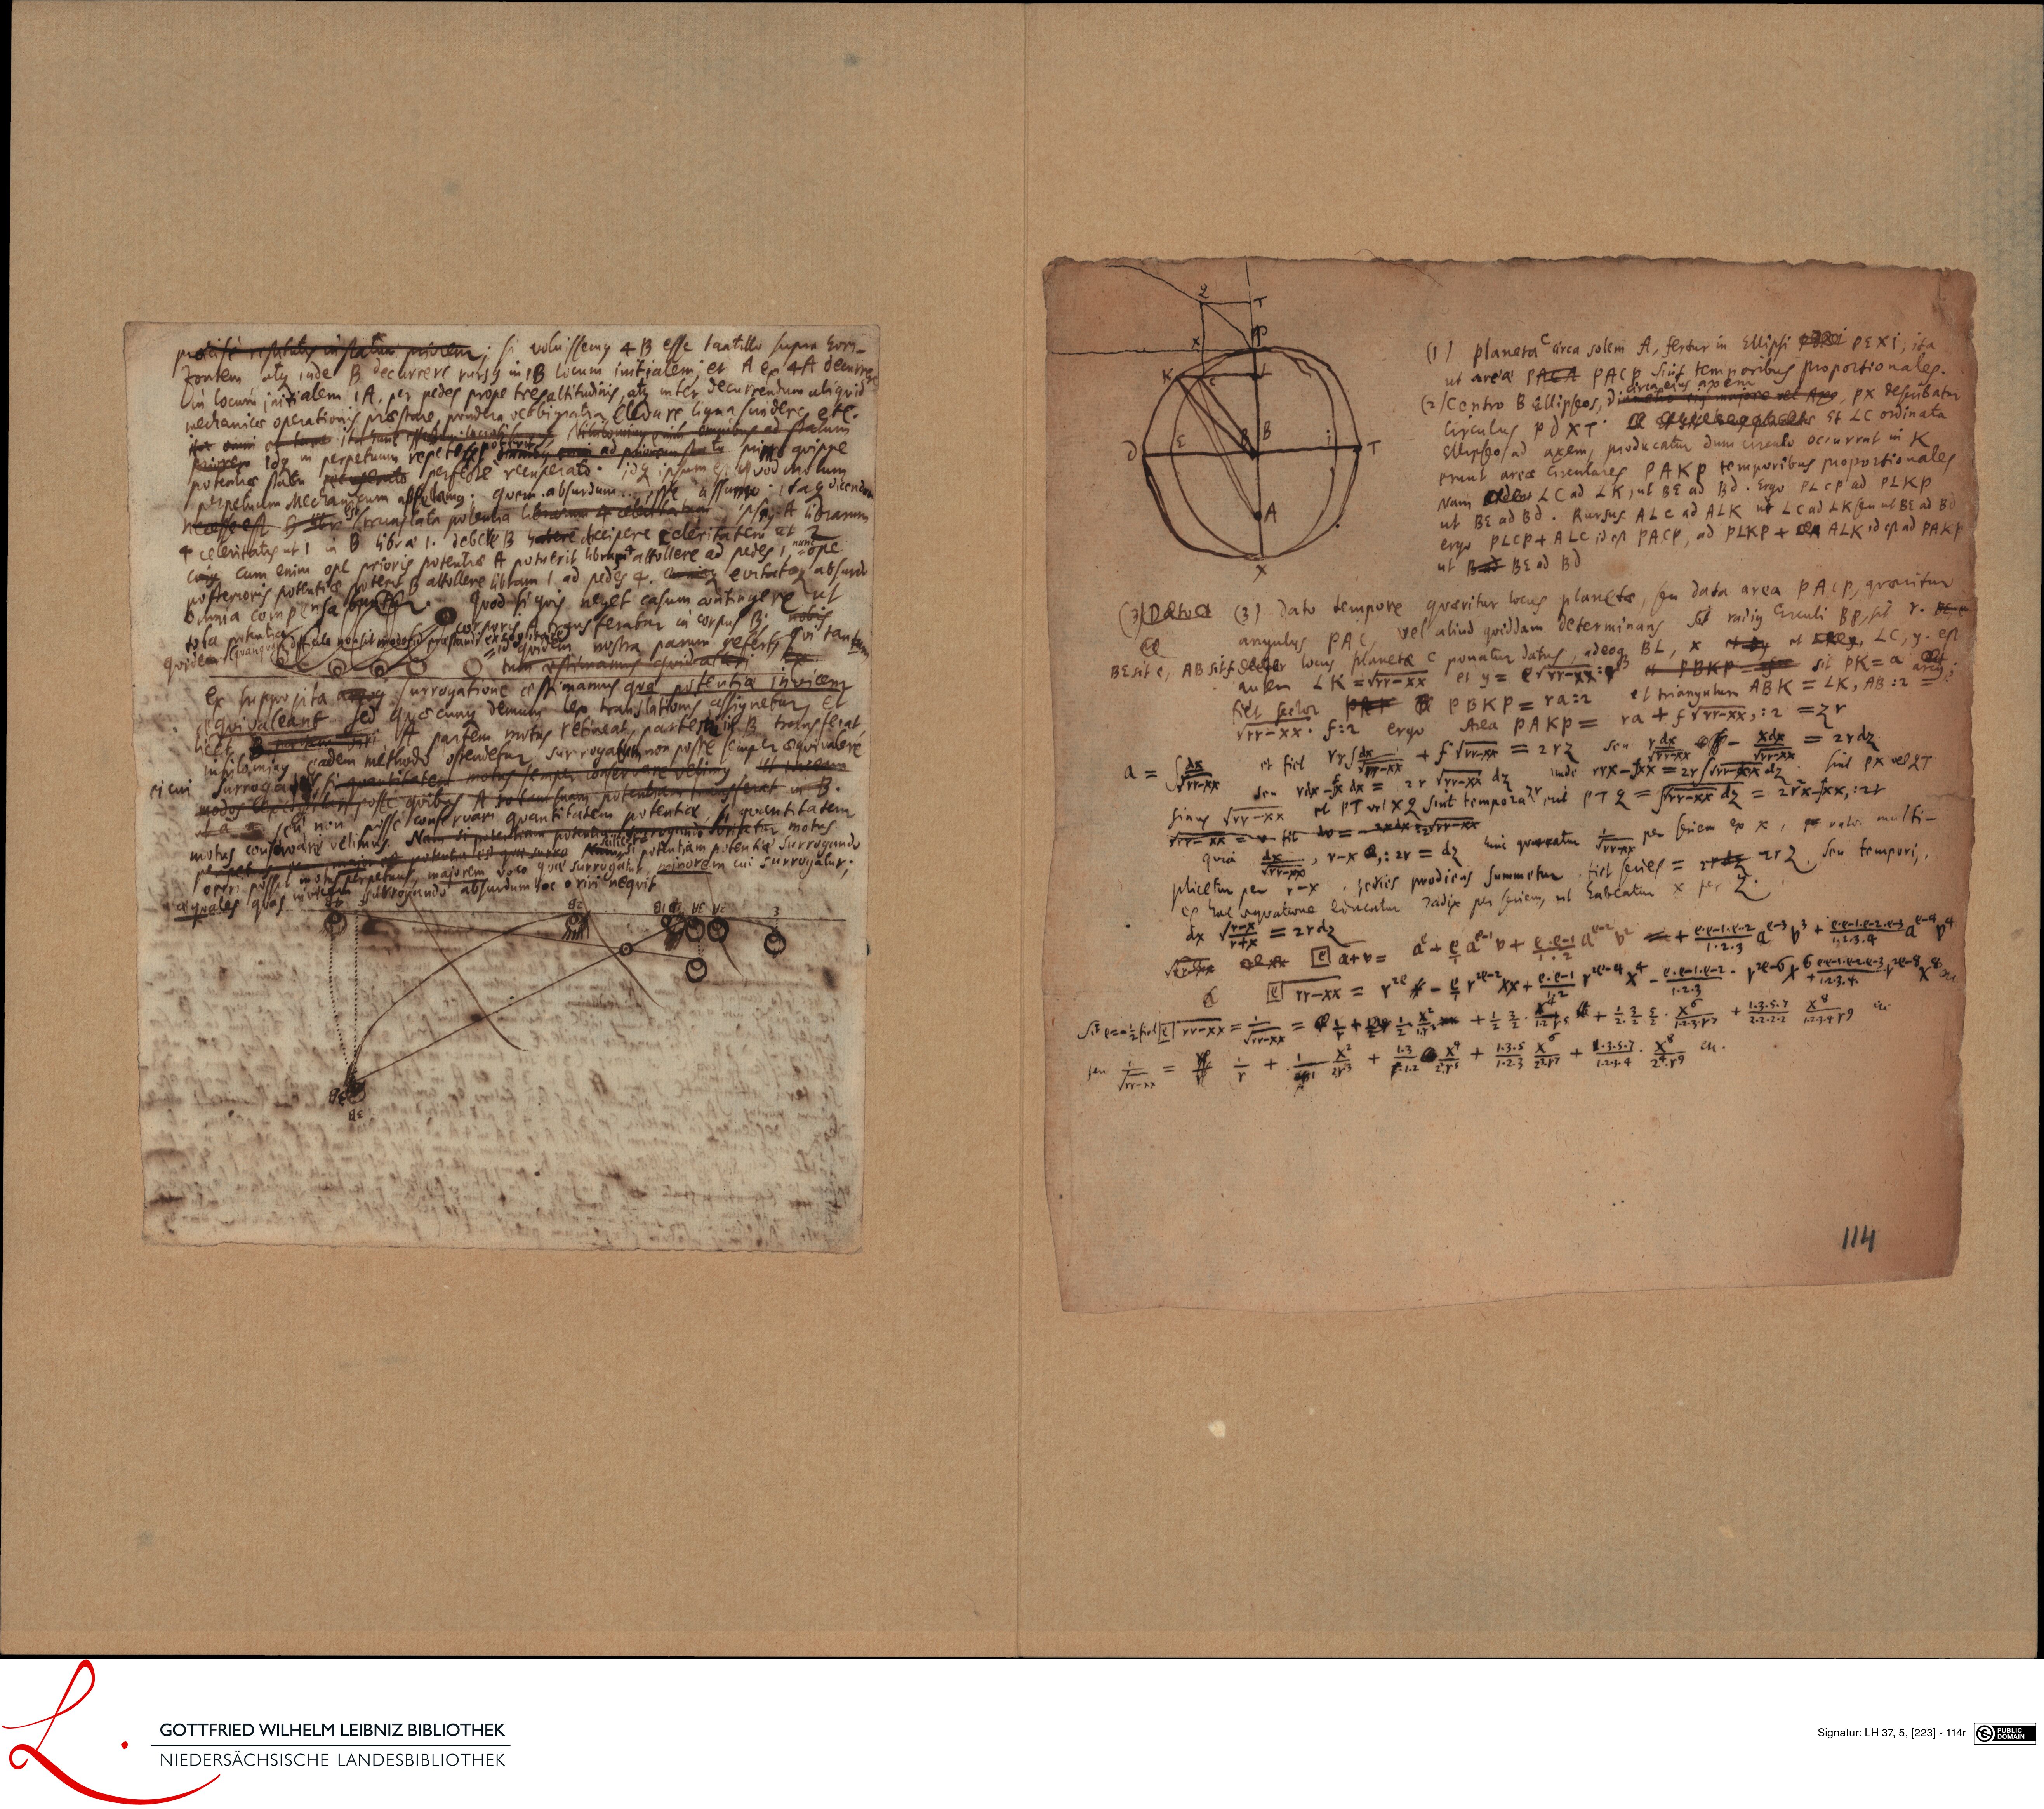
One image of two folio pages side by side, registered by the library under both labels (also fol. 115v); this page is its right half.
The machine reads it as
- (1) planeta circa solem A, fertur in Ellipsi D PEXI, ita
- ut areae PACA PACp sint temporibus proportionales.
- irca ejus axen
- (2)Centro B allipseos, diametro ejus majoro vel Ax, pX describatur
- circulus pdXF. Et LC ordinata
- Ellipseo) ad axem, producatur dum circudo occurrat in K
- erunt areae circulares PAKP temporibus proportionales
- Nam LC ad LH, ut BE ad Bd. Ergo PL CP ad PLKp
- ut BE ad Bd. Rursus AL C ad ALK ut LC ad LK seu ut BE ad BC
- ergo PLCP + ALC id est PACP, ad PLKP + A ALK id est ad PAL p
- ut B ad BE ad Bd
- (3)at (3) dato tempore quaritur locus planetae, seu data area PACp, quaeritur
- angulus pAC, vel aliud quiddam determinans sit radius circuli BP, sit Y. BC, C
- BEsit C, AB sit f decter locus planetae C ponatur datus, adeoque BL, X et By et L, LC, y. est
- autem LK = fr - XX et y = eFrr. x: Y et PBKP s sit BK = a
- fiet sector PAF PBK P = ra : 2 et triangulum ABK = LK, AB: 2 =
- Vrr = XX. f: 2 ergo Area PAKp = ra + fYYr XX, : 2 = ZY
- Somex
- et fiet Yysdx + f Vir = 2YZ seu rdx - Xdx = 2rdz
- X
- srrxx
- seu rix dx = 2r errx dZ unde rVX -ZnX = 2Y (srr. dX dq. sint PX vel 27
- sinus frr-XX et PF vrlX Q sint tempora erit PTZ = prrxx dque = 2rX (XX, : 2+
- quia dx r-x a,: 2Y = dque hinc quaeratur per seriem ex X, valo multi-
- Ver - xx = fit do = - 2X x sir x
- plicetur per r-X. jedies prodiens summetur. fiet secies = e dq 2rZ seu tempori.
- Trrx
- est hac aequatione doncatur radix per seriem, ut habeatur X per L
- (e at v = a + e a v + C. e1 a V + C. p. 116. 2 13 17 + al e. 2. 3 B. 4 4
- ax YI = 2r dZ
- vn
- . 2. 3
- seu q = x + p
- Vir n
- 1,23. 4
- set rr- XE 2 rE X - C r xx + C. C 1 p. 4 - P. E. 1. 8- 2. pre 67 6 exr vr a3, pe 8,
- 2.3
- + 12.3. +.
- Sit exai folse) rruxx = = = + + + Z. 5 H + 2. 2E arr 2
- er
- F.1.2
- Er
- 2
- inna Dro cu.
Cite
Leibniz-Handschriften zur Mechanik: Dynamika LH 37, 5, fol. 114r. Machine transcription, not an edition: Leibniz Legible (model FoNDUE-GD_v2_ft_Leibniz, run 74). https://leibnizlegible.com/page/00068534:0223?run=74